
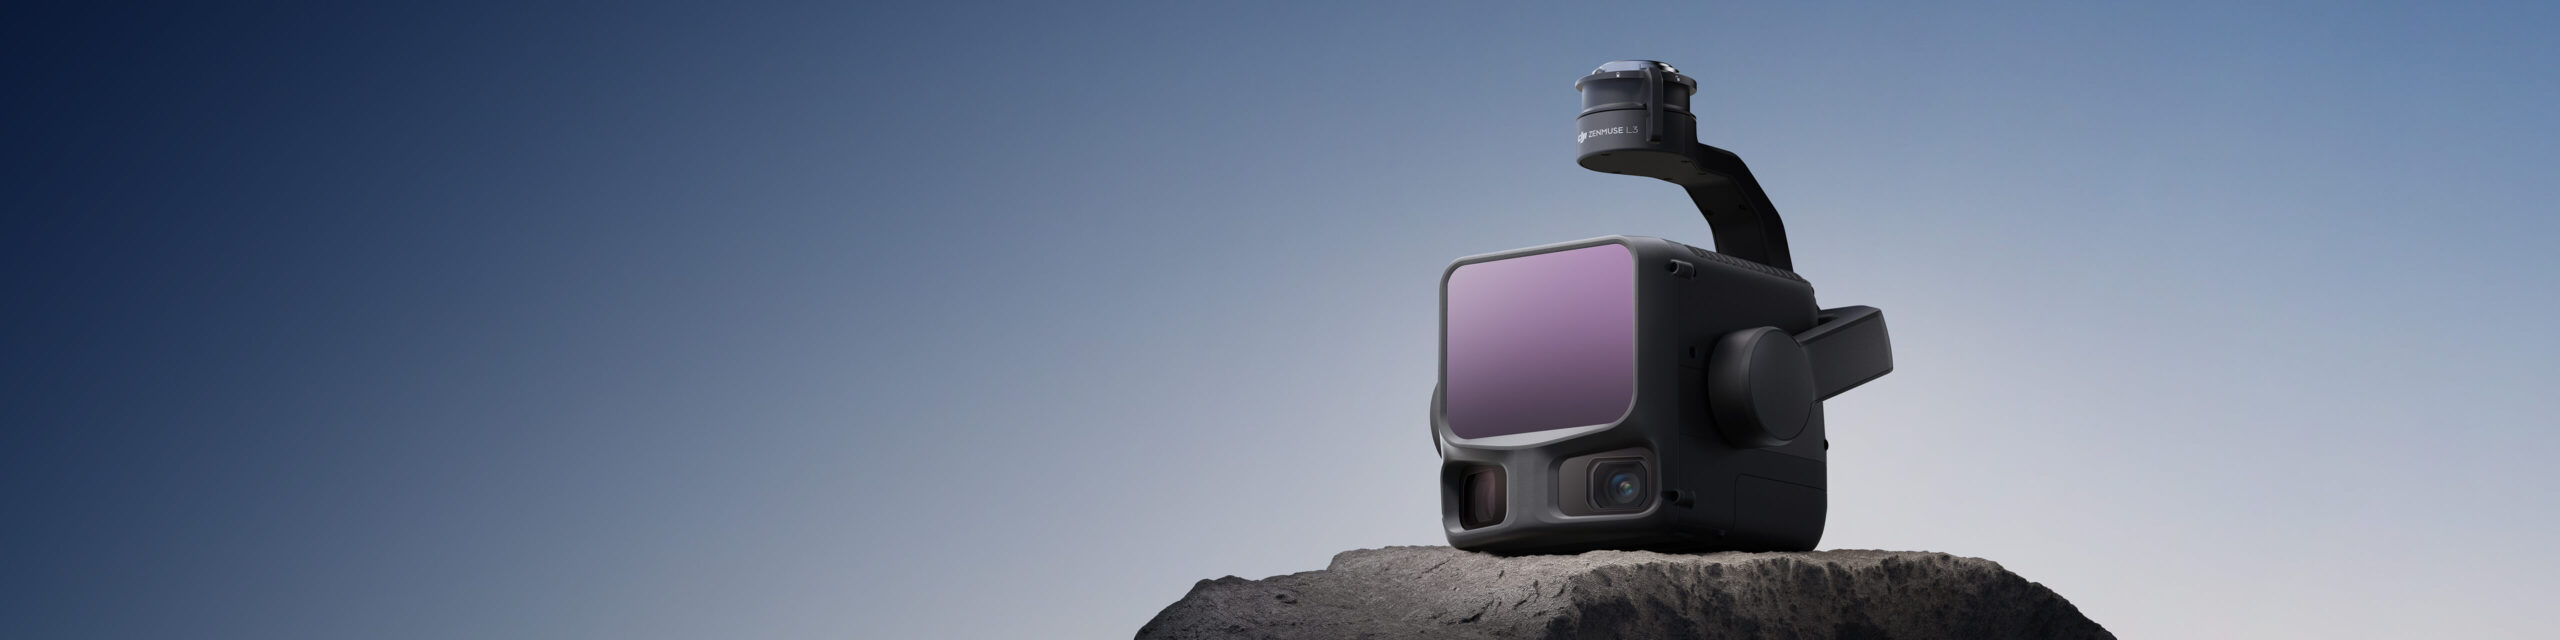
Zenmuse L3
See Farther, Capture Reality
DJI's first long-range, high-precision aerial LiDAR system. It offers a detection range up to 950 metres even on objects with just 10% reflectivity.[1]
Dual 100 MP RGB mapping cameras and a high-precision POS system accelerate geospatial data capture, enabling mapping of up to 100 km² per day.[2]
- Long-range LiDAR
- 1535 nm
- Detection range at 10% reflectivity
- 950 m[1]
- Dual RGB mapping cameras
- 2 × 100 MP
- Up to 2 million pulses per second
- 2 MHz[3]
- Maximum supported returns
- 16[3]
- Daily mapping capacity
- 100 km²[2]
Maximum values apply to different operating settings and test conditions. Measurement conditions are explained at the end of the page.
Long Range,
Wide Coverage
Zenmuse L3 reaches a maximum detection range up to 950 m in tests at a 100 kHz pulse rate, 100 klx ambient light and 10% target reflectivity.[1]
An adjustable pulse rate provides flexible power output and adapts to different operations. Typical flight altitudes of 300–500 m expand single-flight coverage and improve mapping efficiency.
Detection distance differs from flight altitude. DJI's default maximum detection limit is 900 m; contact an authorised dealer for longer range. Flight altitude is subject to local flight rules and permissions.
Small Beam Spot,
High Energy
With a beam divergence of just 0.25 mrad (1/e²), Zenmuse L3 produces a laser spot approximately one-fifth the size of Zenmuse L2's at the same distance. This enables detection of small objects such as power lines and tree branches.
Higher energy density improves penetration, increases ground-point density beneath vegetation and enables precise reconstruction of complex terrain and structures.
High Pulse Rate,
Multiple Returns
Zenmuse L3 offers a maximum pulse emission rate of 2 million laser pulses per second and support for up to 16 returns at appropriate frequency settings.[3]
Point-cloud density and penetration can be adjusted to suit requirements from high-precision mapping to complex environments.
16 returns: 100 / 350 kHz. Up to 8 returns: 1000 kHz. 4 returns: 2000 kHz. Maximum pulse rate and maximum return count cannot be used simultaneously.
Scanning for the Site
Zenmuse L3 supports Linear, Star-Shaped and Non-Repetitive scanning modes for different operational scenarios.
Linear
Provides a more consistent point-cloud distribution. Ideal for high-precision terrain mapping.
Star-Shaped
Balances multiple scan angles and high penetration with accuracy. Suitable for forested areas and dense urban environments.
Non-Repetitive
Offers wide scanning angles and broader coverage. Optimised for power-line inspection and other complex structural surveys.
Detail and Precision Together
Dual 100 MP RGB Cameras
Two 4/3 CMOS sensors, mechanical shutters and a combined horizontal field of view of 107°. Average ground sampling distance (GSD) of 3 cm at a 300 m nadir flight altitude.
- Combined horizontal field of view
- 107°
- Average GSD at 300 m
- 3 cm
High-Precision POS
Position and orientation data are processed alongside LiDAR measurements. Under the specified test conditions, point-cloud vertical accuracy is 3 cm at 120 m flight altitude and 5 cm RMSE at 300 m.[4]
- Vertical accuracy at 120 m
- 3 cm[4]
- Vertical accuracy at 300 m
- 5 cm[4]
From the Field to Processed Data
Complementary hardware and software for flight planning, data capture and point-cloud processing.
Compatible with DJI Matrice 400
Zenmuse L3 is used on DJI Matrice 400 with the Zenmuse L3 single gimbal connector connected to the E1 port beneath the aircraft.
DJI Pilot 2
Flight planning and field data capture.
DJI Terra
Process LiDAR and RGB data and prepare point-cloud outputs.
DJI Modify
Point-cloud editing and application workflows.
Technical Specifications
Select a heading to explore system, LiDAR, RGB camera and positioning specifications.
System and Compatibility
| Supported aircraft | DJI Matrice 400 |
|---|---|
| Connection | Zenmuse L3 single gimbal connector; E1 port |
| Weight | 1.60 kg (excluding single gimbal connector) Connector: 145 g |
| Dimensions (L × W × H) | 192 × 162 × 202 mm In the default stabilised state after power-on. |
| Power consumption | Typical: 64 W Maximum: 100 W |
| Protection rating | IP54 |
| Operating temperature | −20 °C to +50 °C |
| Storage temperature | −40 °C to +70 °C |
The IP54 rating was determined under controlled laboratory conditions and may decrease with use and wear.
LiDAR and Scanning
| Laser wavelength | 1535 nm |
|---|---|
| Beam divergence | 0.25 mrad (1/e²) |
| Laser spot diameter | 41 mm at 120 m 86 mm at 300 m (1/e²) |
| Detection range[1] | 10% reflectivity, 350 kHz: 700 m 10% reflectivity, 100 kHz: 950 m 80% reflectivity, 100 kHz: 2000 m Default maximum detection limit: 900 m. |
| Minimum effective detection distance | 10 m |
| Distance measurement accuracy | Absolute accuracy: ±10 mm Repeatability: <5 mm (1σ) |
| Pulse rate and recommended flight altitude | 100 kHz: <500 m 350 kHz: <300 m 1000 kHz: <100 m 2000 kHz: <50 m |
| Number of returns[3] | 100 / 350 kHz: 4, 8 or 16 1000 kHz: 4 or 8 2000 kHz: 4 |
| Linear scanning field of view | Horizontal: 80° / Vertical: 3° |
| Star-shaped scanning field of view | Horizontal: 80° / Vertical: 80° |
| Non-repetitive scanning field of view | Horizontal: 80° / Vertical: 80° |
| Laser safety class | Class 1 (IEC 60825-1:2014) |
Distance measurement accuracy: 25 °C, 350 kHz, 80% target reflectivity; test distances of 120 and 300 m. This differs from processed point-cloud system accuracy.
Dual RGB Mapping Cameras
| Camera system | Dual 100 MP RGB cameras; each with a 4/3 CMOS sensor |
|---|---|
| Equivalent focal length | 28 mm |
| Aperture | f/2.0 – f/11 |
| Single-camera field of view | Diagonal: 73.3° Horizontal: 62° / Vertical: 41.2° |
| Combined horizontal field of view | 107° Angle between the optical axes of the two cameras: 45° |
| Photo dimensions | 100 MP: 12,288 × 8,192 pixels 25 MP: 6,144 × 4,096 pixels |
| Mechanical shutter | f/2.0: 2–1/1500 s f/2.8–f/11: 2–1/2000 s Shutter count: 500,000 |
| Electronic shutter | 2–1/16000 s |
| Minimum photo interval | JPEG / 25 MP: 0.5 s JPEG / 100 MP: 1 s RAW or JPEG + RAW: 1.2 s |
| Video | 4K: 3840 × 2160 / 30 fps FHD: 1920 × 1080 / 30 fps MP4 (HEVC / H.265) |
| Average GSD | 3 cm at 300 m nadir flight altitude |
Accuracy and POS System
| Point-cloud accuracy at 120 m[4] | Vertical: 3 cm RMSE Horizontal: 4 cm RMSE |
|---|---|
| Point-cloud accuracy at 300 m[4] | Vertical: 5 cm RMSE Horizontal: 7.5 cm RMSE |
| Point-cloud thickness | At 120 m nadir flight altitude: 1.2 cm (1σ) At 300 m nadir flight altitude: 2 cm (1σ) |
| GNSS update rate | 5 Hz |
| POS update rate | 200 Hz |
| Orientation error | Yaw: 0.02° Pitch / Roll: 0.01° Post-processed data, 1σ. |
| Positioning accuracy (RTK fix) | Horizontal: 1.0 cm + 1 ppm Vertical: 1.5 cm + 1 ppm |
| PPK differential data formats | DAT (D-RTK 3 / D-RTK 2 base-station mode) RINEX v2.1x / v3.0x RTCM v3.0 / v3.1 / v3.2 / v3.3 (MSM3–MSM7) OEM4 / OEM6 |
Point-cloud thickness: linear scanning, 80% reflectivity, with point-cloud optimisation and downsampling disabled in DJI Terra. DJI specifies a maximum base-station distance of 15 km for PPK; the station must support more than two GNSS constellations.
Gimbal
| Stabilization | 3 axes (pitch, roll, yaw) |
|---|---|
| Angular accuracy | ±0.01° |
| Mechanical range | Pitch: −135° to +73° Roll: −90° to +60° Yaw: −105° to +105° |
| Controllable range | Pitch: −120° to +60° Yaw: −80° to +80° Roll is for stabilisation only and cannot be controlled. |
| Mounting | Detachable DJI SKYPORT; Zenmuse L3 single gimbal connector |
Data Storage and Software
| Recorded raw data | Photographs, IMU, point clouds, GNSS and calibration files |
|---|---|
| Standard memory card | CFexpress Type B Sequential write speed: 1500 MB/s |
| Standard card reader | Read / write speed: >900 MB/s |
| Data capture | DJI Pilot 2 |
| Data processing | DJI Terra |
| Data applications | DJI Modify |
| Cloud application | DJI FlightHub 2 |
| DJI Terra point-cloud export | PNTS / LAS / LAZ / PLY / PCD / S3MB |
| DJI Modify point-cloud import | LAS |
- Range: The 950 m figure applies at 10% target reflectivity and 100 kHz. Test conditions: 100 klx ambient light, centre of field of view, flat target larger than the beam diameter, perpendicular incidence and 23 km atmospheric visibility. Range is the distance at which 50% of pulses are detected. Range may decrease with multiple targets. The default limit is 900 m; longer range requires DJI or authorised-dealer support.
- Daily coverage: Up to 100 km² with DJI Matrice 400 on flat terrain, at 300 m nadir flight altitude, 20% side overlap, 17 m/s flight speed and a total of 6 hours of effective flight time. This is not continuous single-flight endurance or single-battery capacity.
- Pulse rate / returns: 4 / 8 / 16 returns at 100 and 350 kHz; 4 / 8 at 1000 kHz; 4 at 2000 kHz.
- System accuracy: DJI laboratory test: Matrice 400 connected to a position-calibrated D-RTK 3, DJI Pilot 2 area route, IMU calibration enabled, linear scanning, 15 m/s, gimbal at −90°, straight route segments shorter than 3300 m. Diffuse-reflective check points on open hard ground were used, with point-cloud accuracy optimisation enabled in DJI Terra. Field results may vary.
Product information: DJI Zenmuse L3 specifications · Compatibility and usage information
About Zenmuse L3
Request Detailed Information
Contact our specialists for a suitable LiDAR solution, product specifications and a quotation for your project.